Biomimetic Skeletal Kinematics
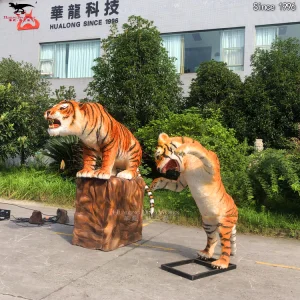
Modern simulated roaring tigers utilize high-torque, brushless servo motors coupled with multi-axis planetary gearboxes. Unlike archaic pneumatic cylinders that create jerky motions, servo drives allow smooth transitions across the mandibular, scapular, and spinal joints, recreating genuine feline gait and snarl kinematics.
Sub-millimeter Positioning
Silent Gearing
Kinematic Smoothness